← Catalog
Connector insertion with position-error recovery
Airion
- Episodes
- 1,200
- Hours
- 18.4 h
- Format
- LeRobot v2
- Robot
- UR5e, parallel gripper
- Quality report
- A · Ready for training
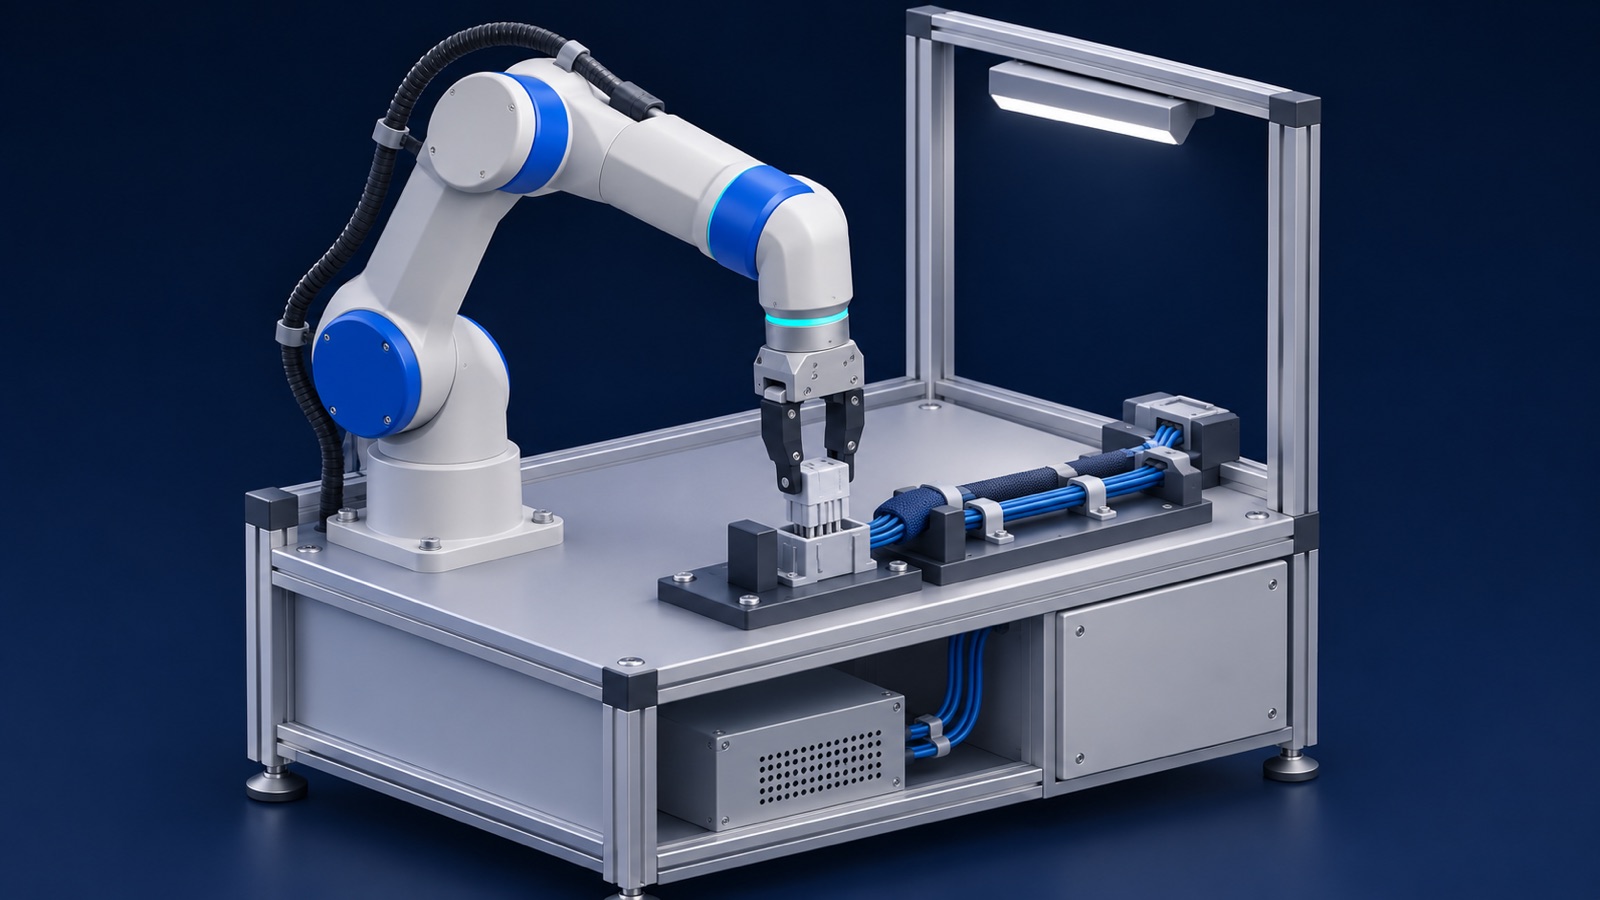
Leader-follower teleoperation of connector insertion on a live wire-harness line. Operators recovered from misaligned grasps and partial insertions, so failures and recoveries are labelled per episode.
Episodes
1,200 episodes in total
- Success 70%840 episodesCompleted the task as intended
- Failure 20%240 episodesDid not complete the task
- Recovery 10%120 episodesWent wrong, then recovered and completed
Data
- Task
- Insertion and assembly
- Robot
- UR5e, parallel gripper
- Cameras
- RealSense D435 ×3
- Signals
- RGB · Force-torque · Joint states
Quality report
AReady for training
All 1,200 episodes open in LeRobot v2 with synchronized timestamps. Failure and recovery labels were spot-checked on 60 episodes and matched. One wrist camera is slightly overexposed in about 5% of episodes.
Assessed by Airion when the dataset was checked.
What you can do
- Research and evaluation in your company
- Share within your company
- Commercial use
- Offer trained models to others
- Not allowed: Redistribute or resell the raw data
- Not allowed: Exclusive (not sold to other buyers)